
Definition
Relative velocity is the velocity of an object as observed from the reference frame of another object. Because motion is not absolute, the velocity of any object always depends on the observer describing that motion. When two objects move through space, each perceives the velocity of the other through vector subtraction of their individual velocities measured relative to a common reference, typically the ground.
The Relative Velocity Equation
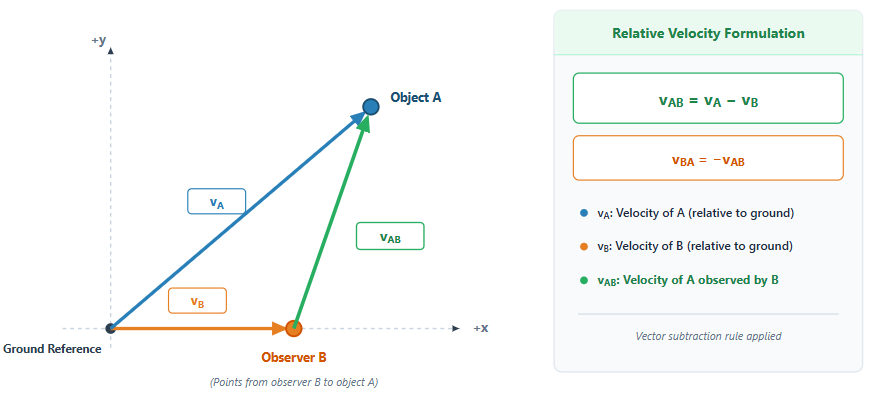
Consider two moving objects, A and B, whose velocities relative to the ground are denoted by and .
The relative velocity of object A as observed by object B is designated by the subscript notation (velocity of A relative to B) and is defined by the vector equation:
Where:
- is the velocity of object A relative to object B
- is the velocity of object A relative to the ground
- is the velocity of object B relative to the ground
Similarly, the velocity of object B as observed by object A is given by:
Comparing these two equations demonstrates an essential directional symmetry:
The magnitude of the relative velocity observed by either body is identical, but the perceived directions are strictly opposite.
Relative Velocity in One Dimension
When objects move along a single straight line, vector arrows simplify to algebraic signs (+ or -) representing forward or backward directions along the coordinate axis.
1. Objects Moving in the Same Direction
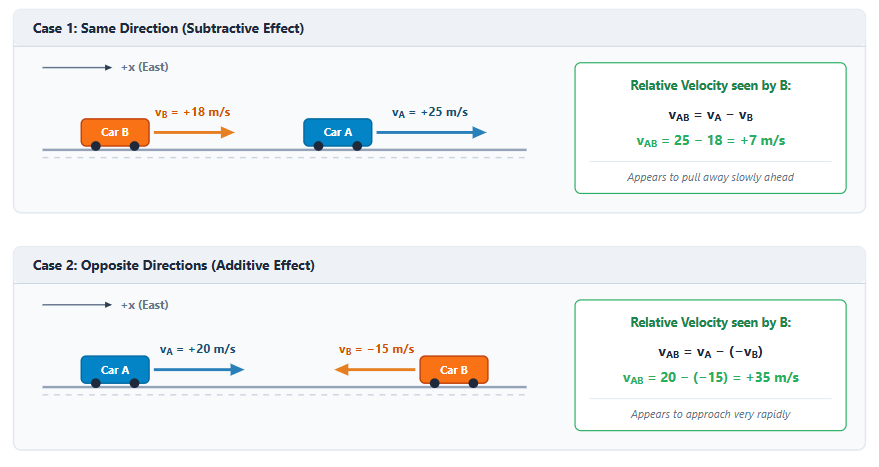
When object A and object B move along the same direction, the relative velocity represents the difference between their speeds:
If two vehicles travel in the same direction, each appears to move much slower to the other than it appears to a stationary bystander on the sidewalk.
2. Objects Moving in Opposite Directions
When object A and object B travel toward each other (or away from each other), their velocities possess opposite signs. Taking the direction of A as positive and B as negative :
The magnitude of their relative velocity equals the sum of their individual speeds. Consequently, approaching vehicles appear to close the gap between them at a significantly higher speed.
Relative Velocity in Two Dimensions
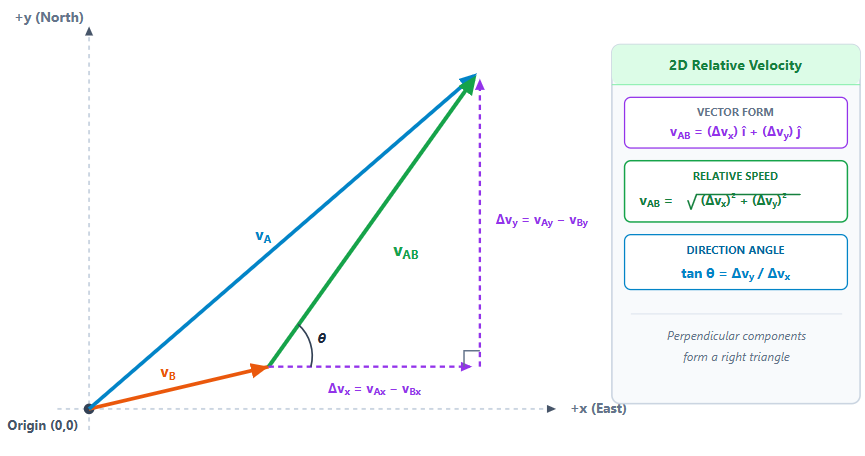
In two dimensions, motion is no longer confined to a single line. The velocities of the objects form arbitrary angles with each other, requiring full vector analysis or resolution into perpendicular components ( and ).
To solve two-dimensional relative motion:
- Establish a standard Cartesian coordinate system (east-west as the x-axis, north-south as the y-axis).
- Resolve each absolute velocity vector into rectangular components: and
- Subtract the corresponding components to determine the relative velocity vector:
- Compute the magnitude (relative speed) using the Pythagorean theorem:
- Determine the directional angle relative to the coordinate axes using trigonometry:
Example 1: Airplane Flying in a Crosswind
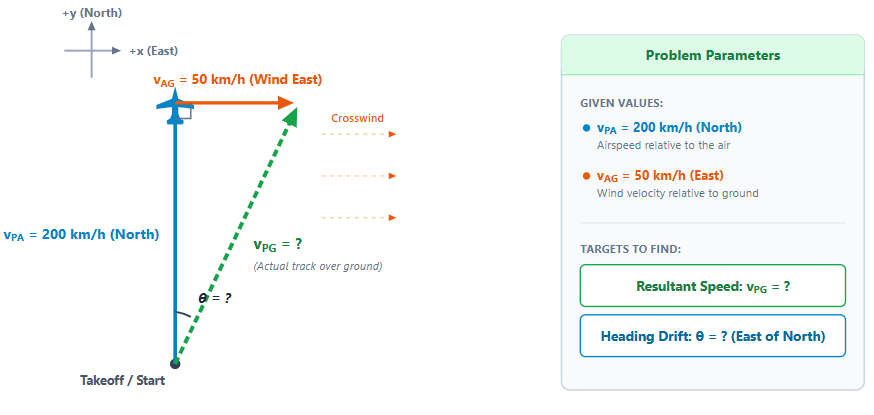
An airplane heads directly north with an airspeed of relative to the air. A steady wind blows toward the east at relative to the ground.
Find the resultant velocity (magnitude and direction) of the airplane relative to the ground.
Resultant Speed Relative to the Ground:
Let east be the positive x-direction and north be the positive y-direction .
The velocity of the airplane relative to the air is:
The velocity of the air (wind) relative to the ground is:
By the relative velocity addition rule, the velocity of the plane relative to the ground is:
Because these two velocity vectors are mutually perpendicular, the speed relative to the ground is calculated using the Pythagorean theorem:
Direction Relative to the Ground:
The heading angle \theta measured east of north is:
The airplane moves relative to the ground at approximately along a track east of north.
Example 2: Boat Crossing a Flowing River
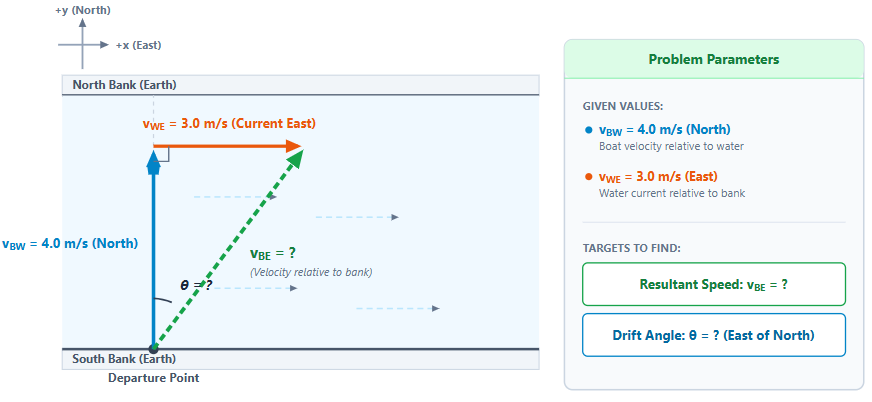
A motorboat heads directly north across a river with a velocity of relative to the water. The river water flows steadily east at relative to the riverbank.
Find the resultant velocity (speed and direction) of the boat relative to an observer standing on the riverbank.
Resultant Speed Relative to the Bank:
Let east be the positive x-direction and north be the positive y-direction .
The velocity of the boat relative to the water is .
The velocity of the water relative to the ground (earth) is .
By the relative velocity addition rule:
Because these two perpendicular vectors form a right triangle, the magnitude of the boat’s velocity relative to the earth is:
Direction Relative to the Bank:
The angle measured east of north is:
The boat travels with a velocity of at an angle of east of north relative to the riverbank.
Key Points
- Relative velocity is the velocity of an object as evaluated from the reference frame of a specific observer.
- The velocity of object A relative to object B is calculated by vector subtraction: .
- Relative velocities between two objects are equal in magnitude but opposite in direction: .
- For one-dimensional motion in the same direction, relative speed is the difference between individual speeds.
- For one-dimensional motion in opposite directions, relative speed is the sum of individual speeds.
- In two-dimensional motion, relative velocity is determined by resolving velocities into perpendicular components or constructing vector addition/subtraction triangles.